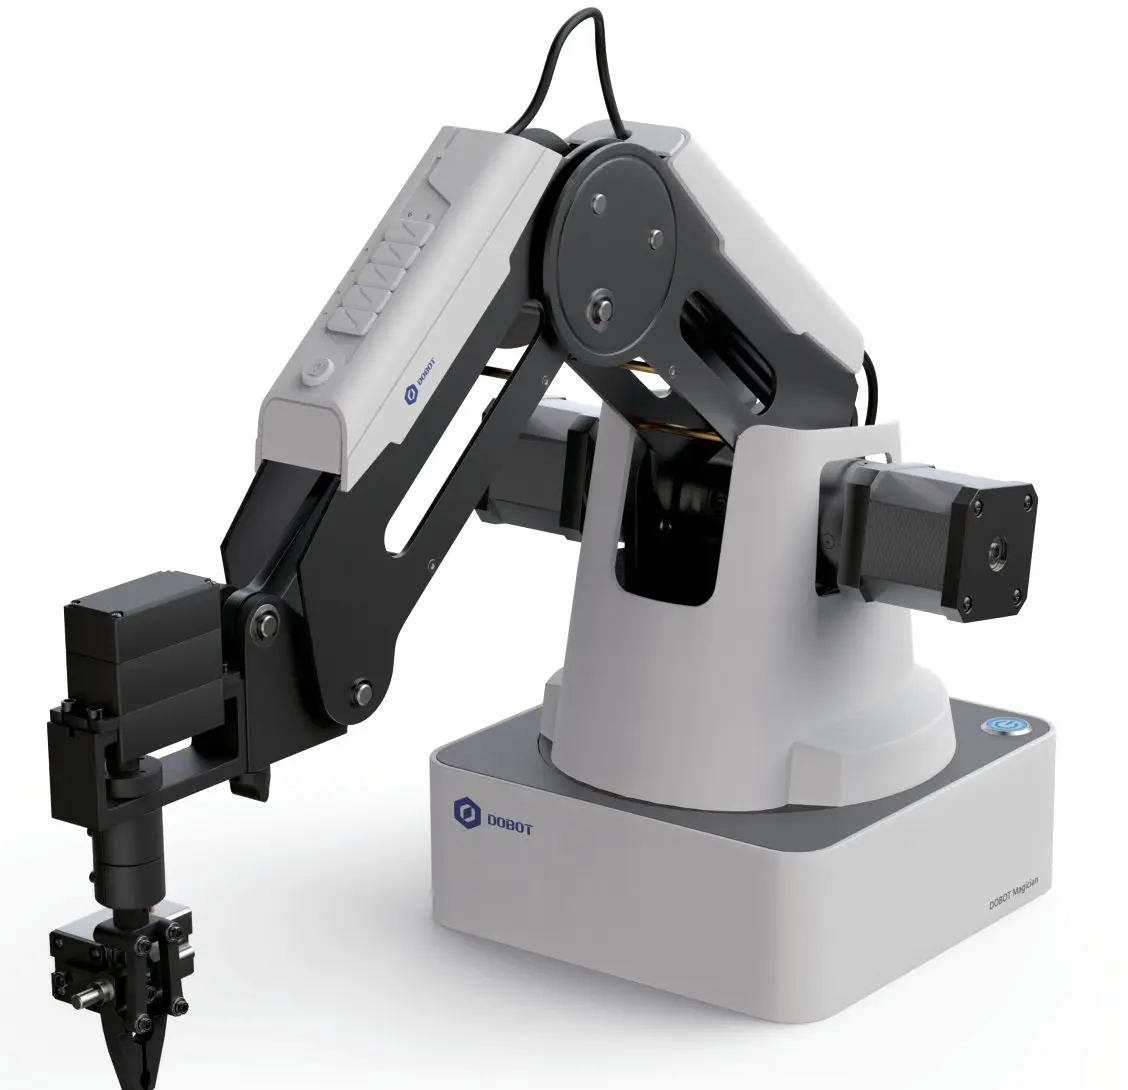
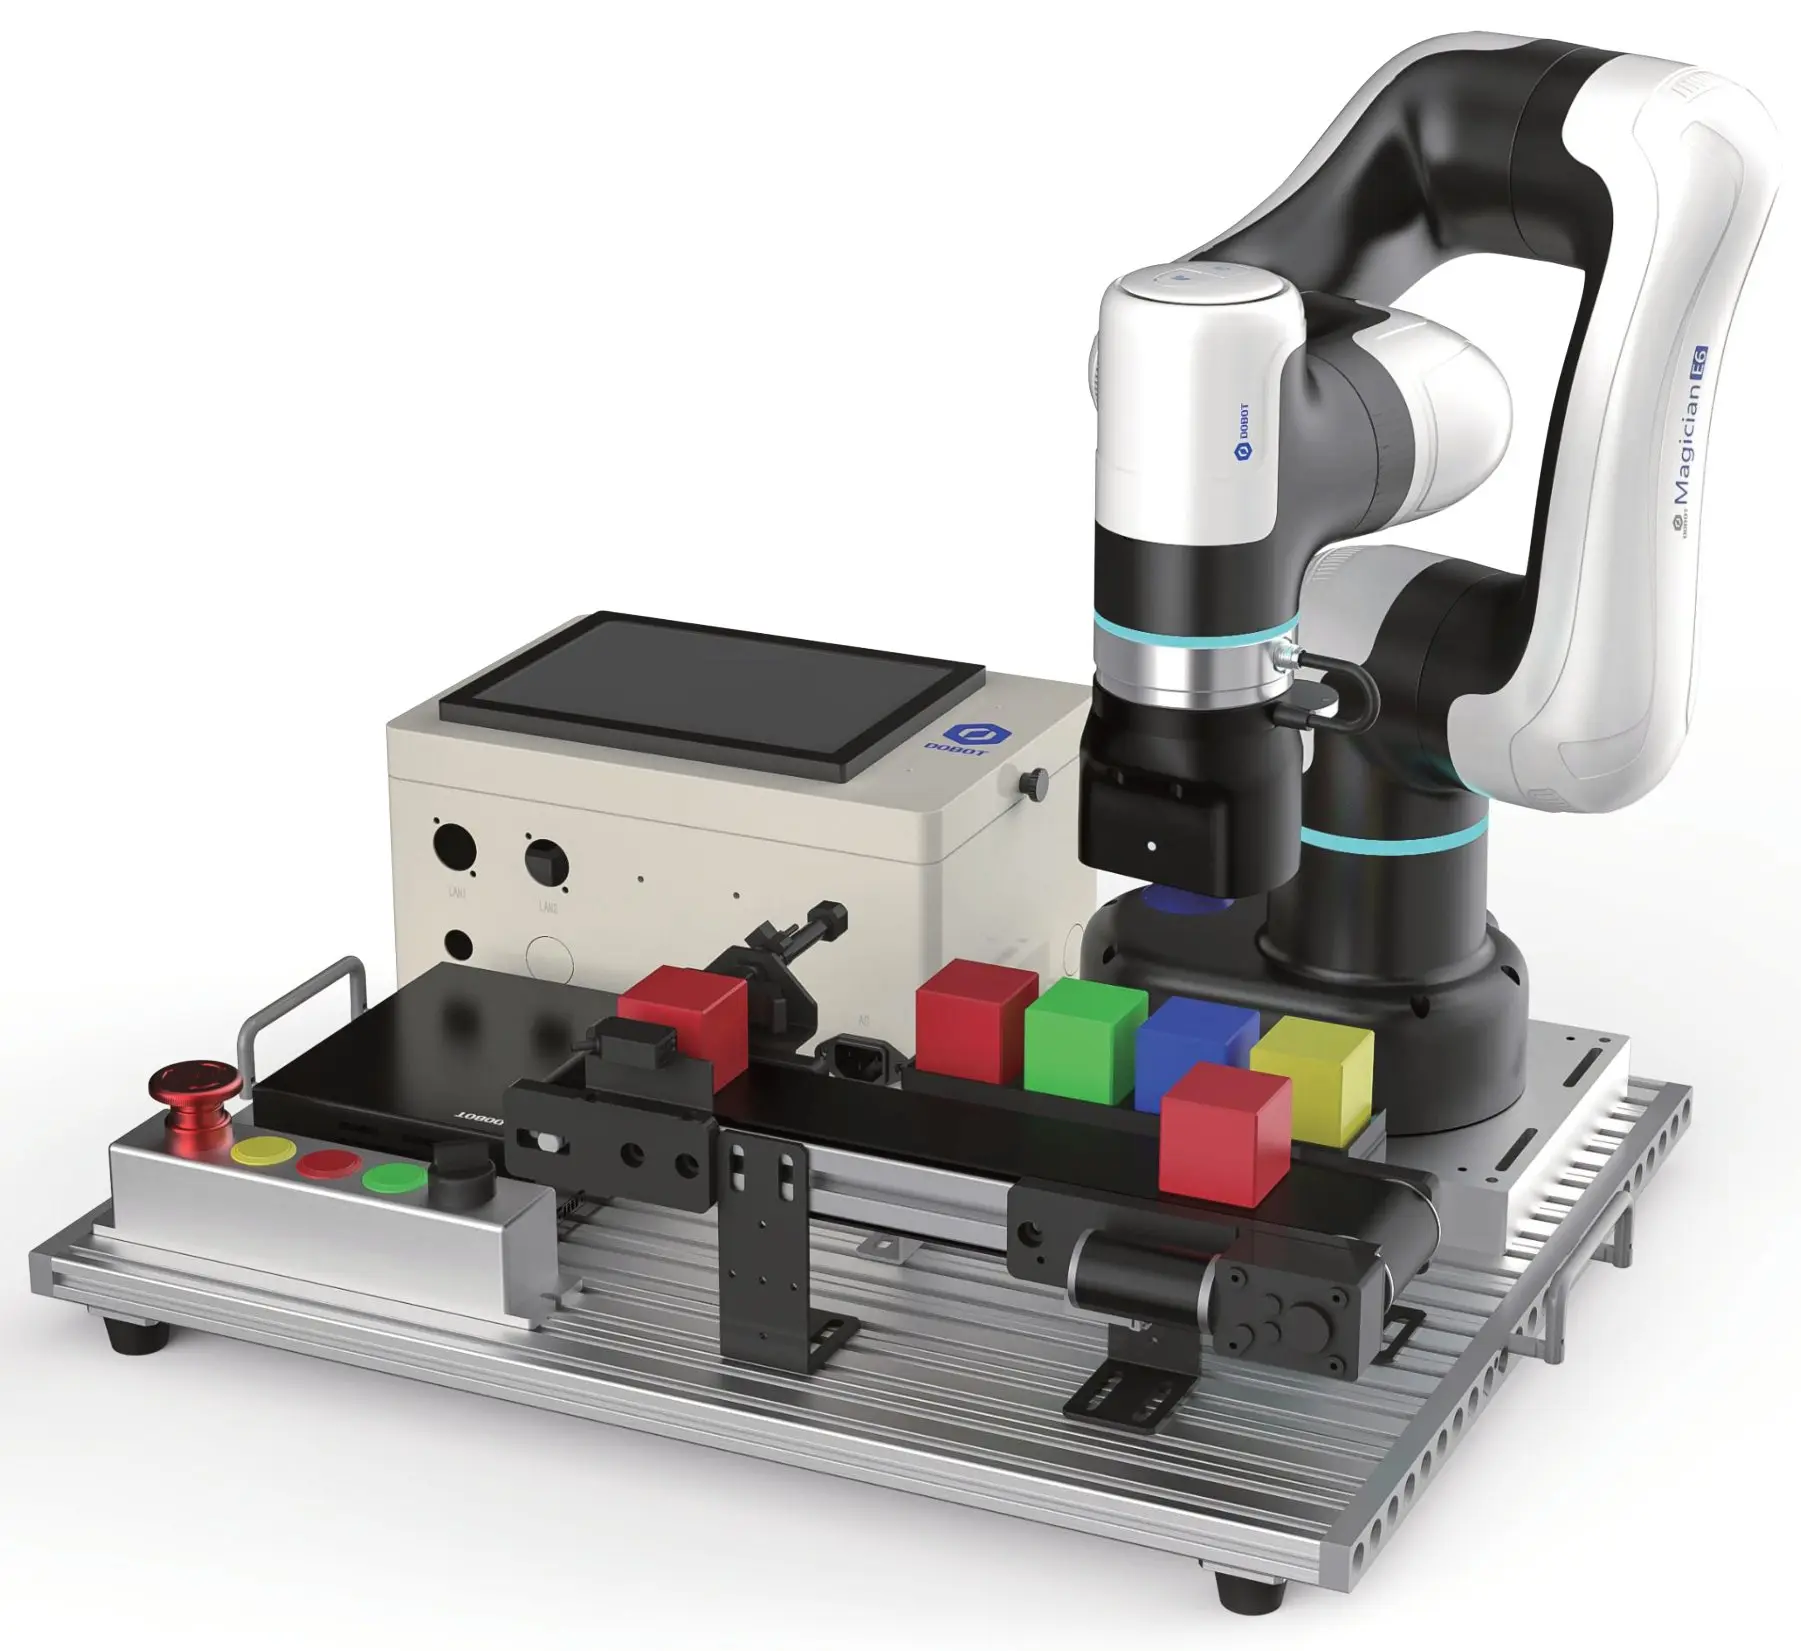
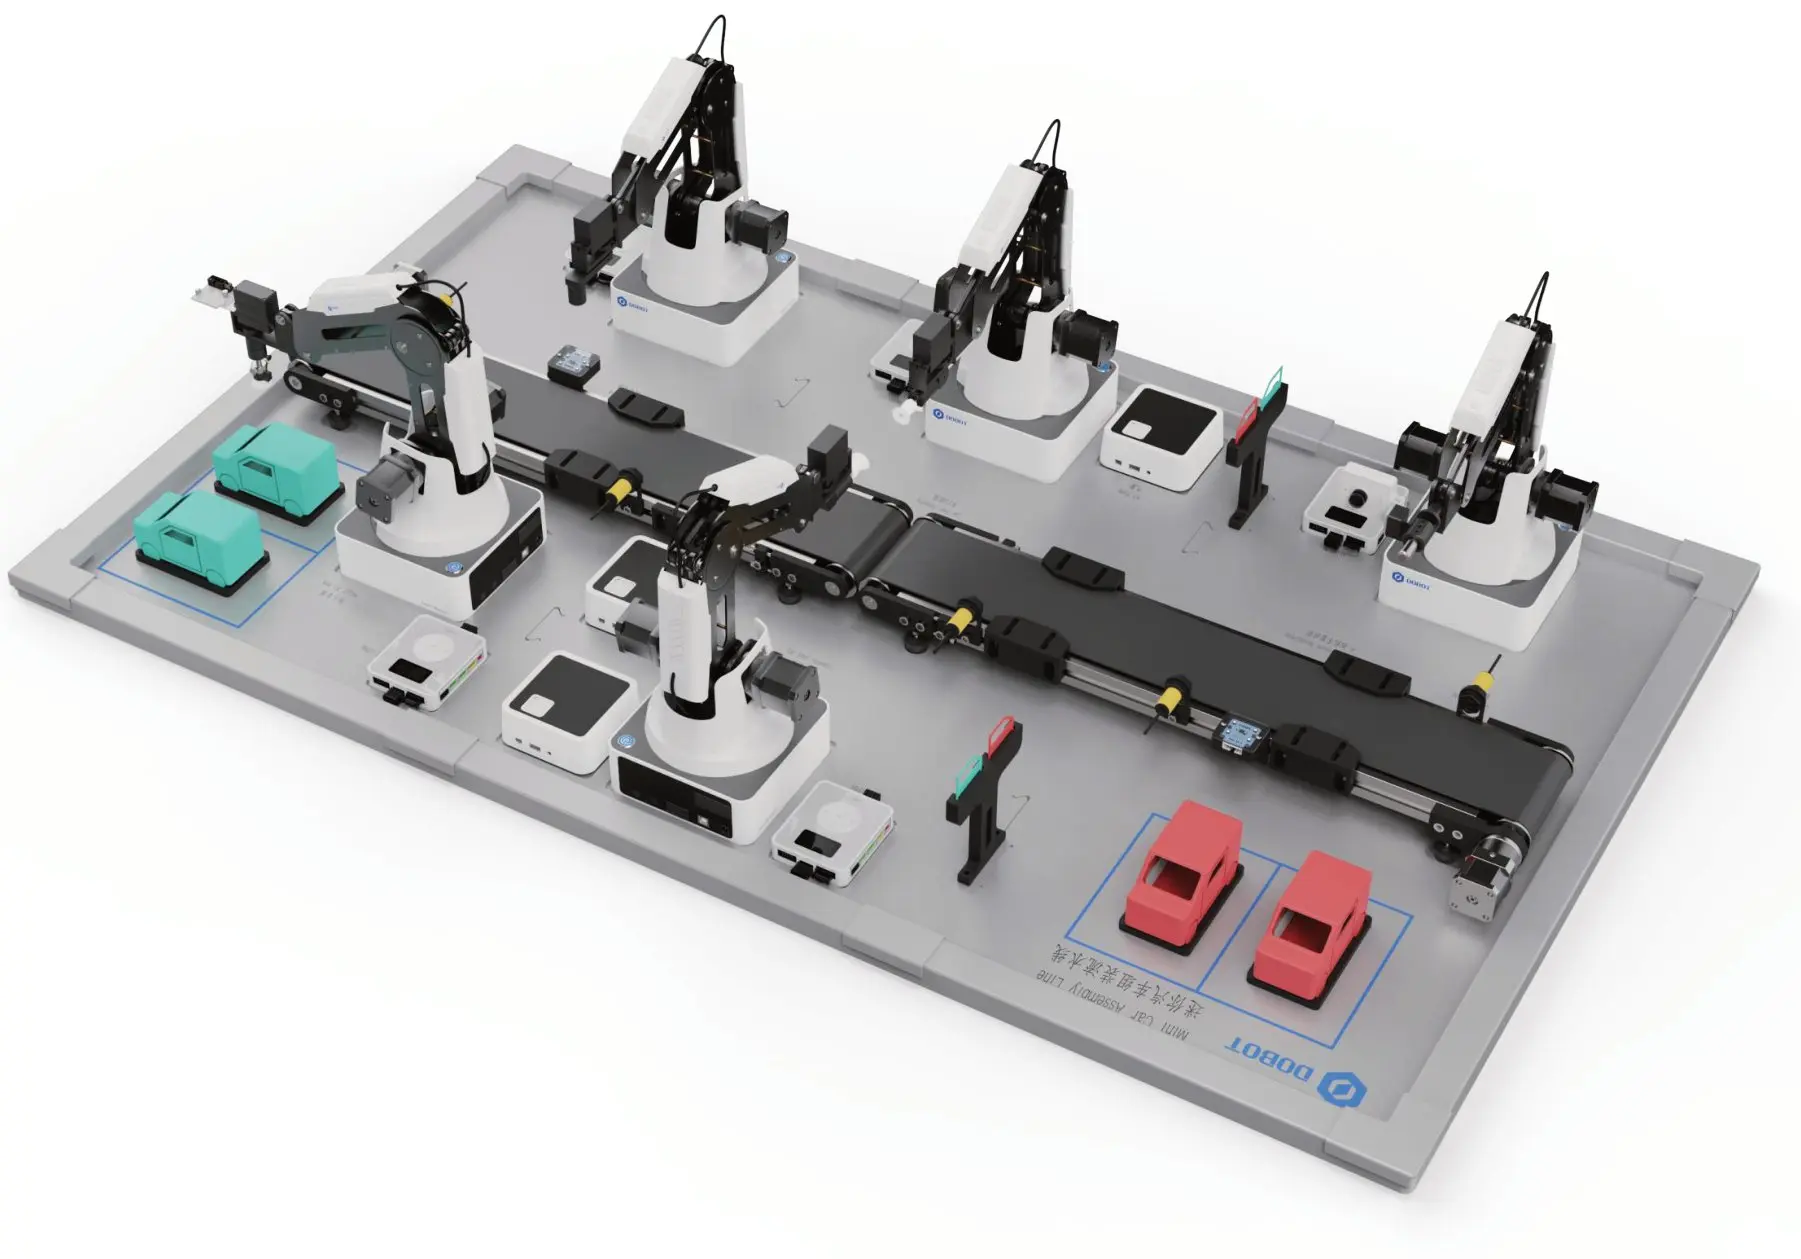
Precision01
Performance & precision
7-DoF humanoid structure with self-developed motors: 4.8 kg body, 3 kg payload, ±0.1 mm repeatability.
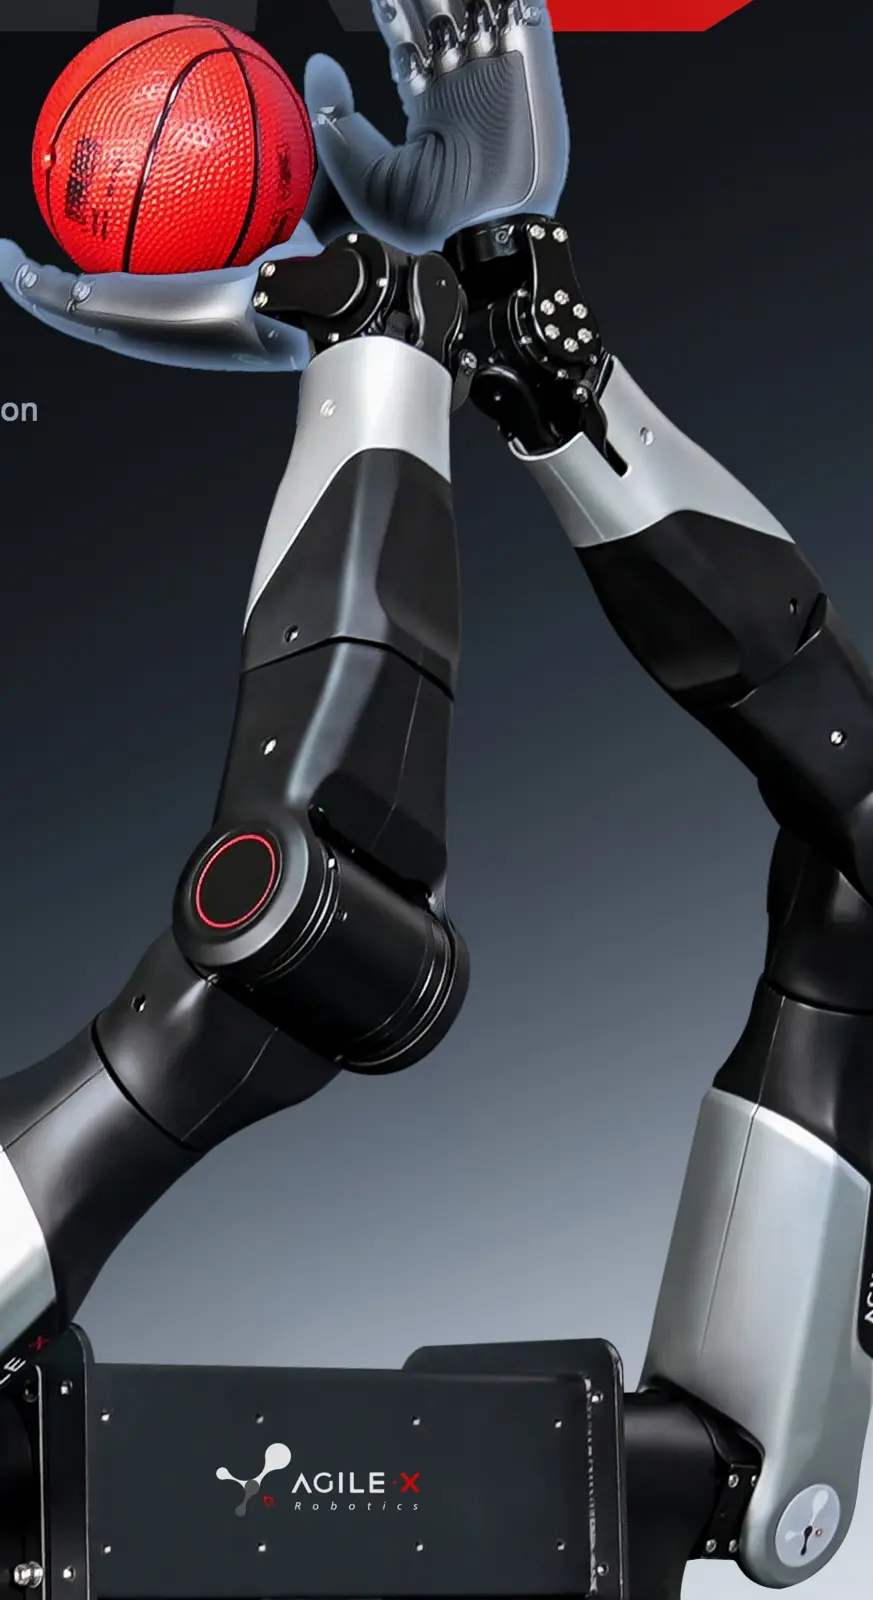
AgileX · Embodied AI
Human-like dexterity, fully open for research.
A fully open, lightweight 7-DoF arm for embodied AI and humanoid robotics.
7
Degrees of freedom
3 kg
Payload
4.8 kg
Body weight
±0.1 mm
Repeatability
Key capabilities
7-DoF humanoid structure with self-developed motors: 4.8 kg body, 3 kg payload, ±0.1 mm repeatability.
CAN/HTTP/TCP; drag-and-teach, offline trajectory and API; Python SDK, ROS1/ROS2; integrates with AgileX chassis.
The seventh degree of freedom achieves dexterous, human-like wrist performance.
Modular interface for grippers, dexterous hands and more.
Delivers high-quality physical interaction datasets for imitation and reinforcement learning.
Supplied, installed, integrated and supported in Egypt by GateIn Technology, exclusive AgileX partner for Egypt.
Explore the hardware
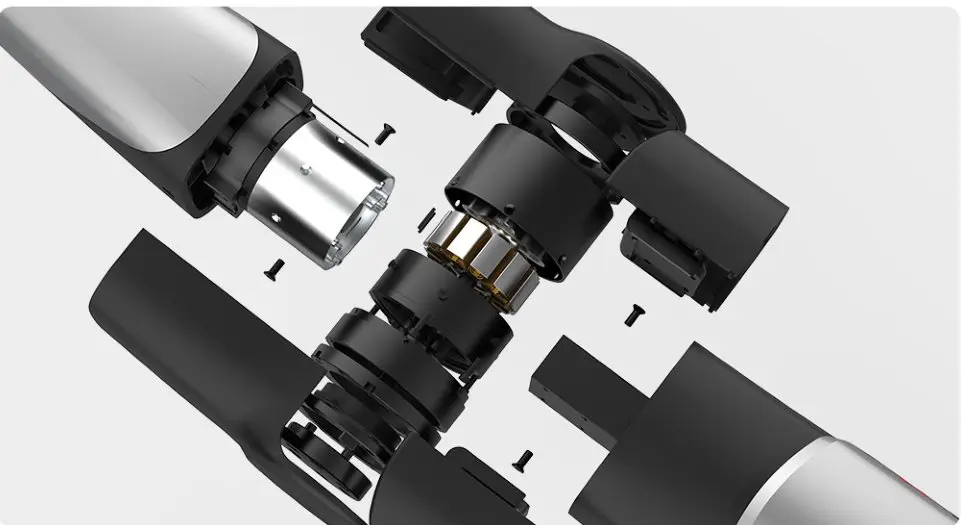
J1–J3 reach 180°/s and J4–J7 reach 225°/s.
Software & control
Program NERO with drag teaching, offline trajectories, API or PC software, then scale to imitation and reinforcement learning with Python and ROS.
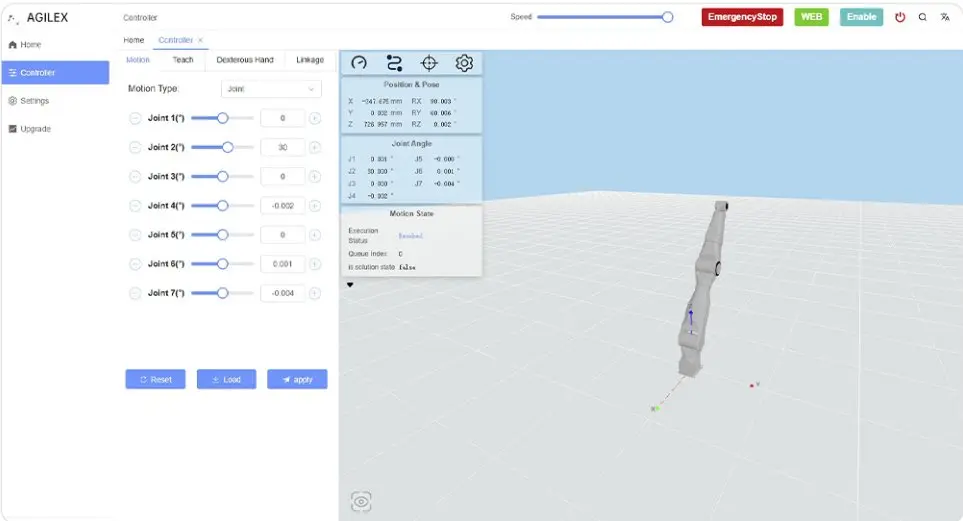
Open development stack for research labs.
Teach motions by hand and replay them.
Multiple communication options for integration.
Application scenarios
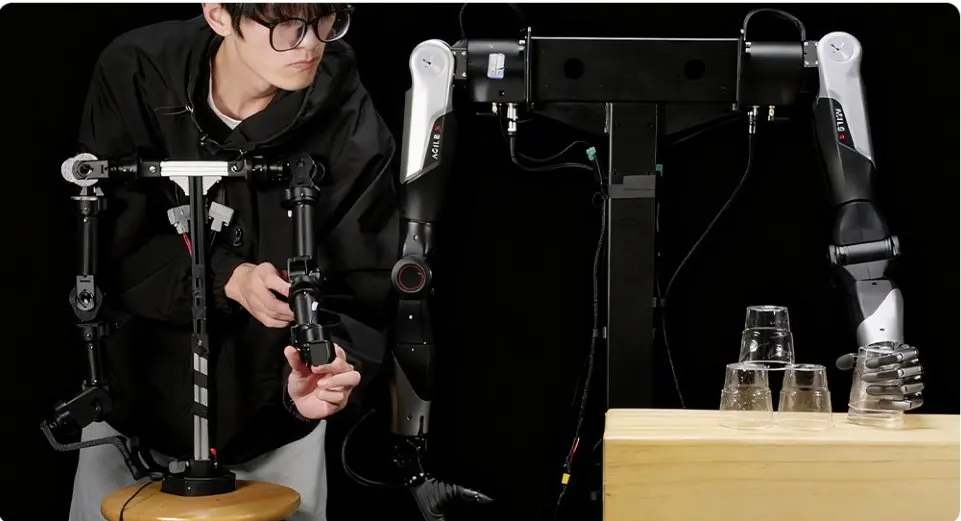
Dual-arm teleoperation and data collection for imitation learning.
Swap grippers and dexterous hands through the open end-effector interface.
Precise physical interaction for training and validating policies.
| Specification | Value |
|---|---|
| DoF · payload · weight | 7 · 3 kg · 4.8 kg |
| Repeatability · reach | ±0.1 mm · 580 mm |
| Input voltage · consumption | DC 24 V · max ≤150 W, average ≤60 W |
| Material · controller | Aluminium & plastic housing · integrated |
| Communication · control | CAN / HTTP / TCP · drag teaching, offline trajectory, API, PC |
| External interface · base | Power × 1, CAN × 1, EtherCAT × 1 · 70 × 70 mm, M5 × 4 |
| Environment · noise · installation | 0–50 °C, 25–85% RH · <60 dB · table / side / upside-down |
| Joint max speed | J1–J3 180°/s · J4–J7 225°/s |
| Joint range | J1 ±157°, J2 −15–190°, J3 ±160°, J4 −60–125°, J5 ±160°, J6 −43–58°, J7 ±90° |
Product gallery
Get in touch
Talk to our integration experts about deploying AI platforms, quantum solutions, robotics, or educational labs across your organization.