Chassis01
TRACER mobile base
685 × 570 × 155 mm, two-wheel differential drive, 100 kg load.
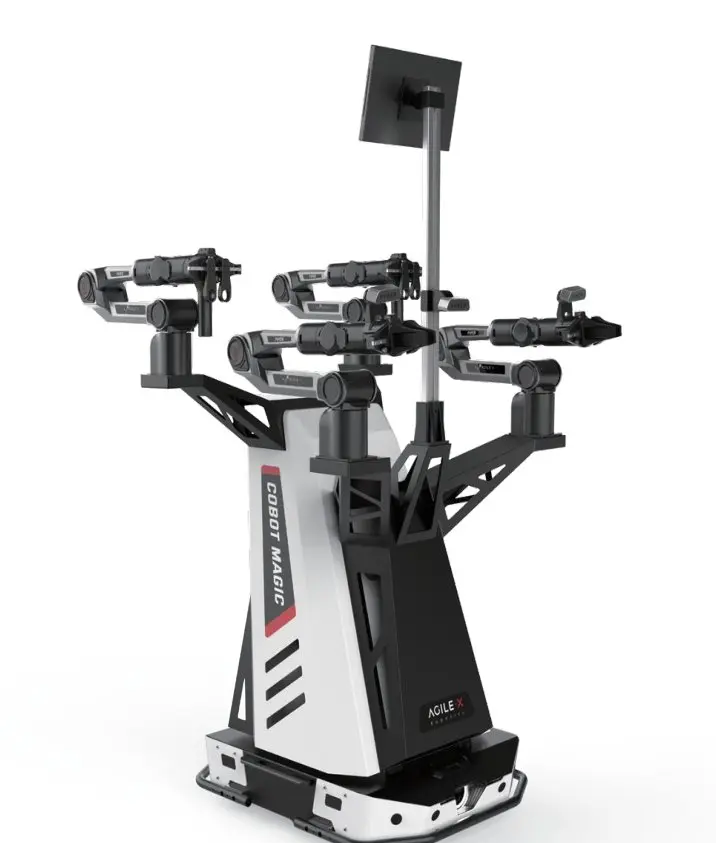
AgileX · Mobile ALOHA
Teach robots with two hands, on the move.
Mobile dual-arm manipulation platform for embodied AI research.
4 ×
PiPER arms
3 ×
Depth cameras
100 kg
Chassis load
RTX 4060
Graphics
Key capabilities
685 × 570 × 155 mm, two-wheel differential drive, 100 kg load.
6 DOF, 653 mm reach, ±0.1 mm repeatability, 1.5 kg payload.
Depth 0.3–3 m and RGB up to 1920 × 1080 @ 30 FPS.
Intel i7-9700, 32 GB RAM, 4 TB SSD, RTX 4060.
Ubuntu 18.04, ROS Melodic, MoveIt, Gazebo and demo packages on GitHub.
Supplied, installed, integrated and supported in Egypt by GateIn Technology, exclusive AgileX partner for Egypt.
Explore the hardware
Two leader and two follower 6-DOF arms with CAN communication.
Application scenarios
Collect teleoperated two-arm demonstrations for Mobile ALOHA policies.
VSCode, Gazebo, MoveIt, rqt, NoMachine and RViz tooling.
Pick-and-place, cooking and organizing objects.
| Specification | Value |
|---|---|
| Robot chassis | TRACER × 1 · 685 × 570 × 155 mm, 28–30 kg, 100 kg load |
| Robotic arm | PiPER × 4 · 6 DOF, 653 mm reach, ±0.1 mm, 1.5 kg payload, 4 kg |
| Camera | Orbbec DaBai × 3 · depth 0.3–3 m, 640 × 400 @ 30 FPS; RGB 1920 × 1080 @ 30 FPS |
| Computer | APQ × 1 · Intel i7-9700, 32 GB RAM, 4 TB SSD, RTX 4060 |
| Operating system · ROS | Ubuntu 18.04 LTS · ROS Melodic |
| Packages | tracer_base, ugv_sdk, camera and gripper packages |
| Specification | Value |
|---|---|
| Documentation | Chassis certificate, chassis manual, secondary development document, sensors manual |
| Software | Chassis model, ROS, Gazebo and open-source demo packages |
Product gallery
Get in touch
Talk to our integration experts about deploying AI platforms, quantum solutions, robotics, or educational labs across your organization.