0101
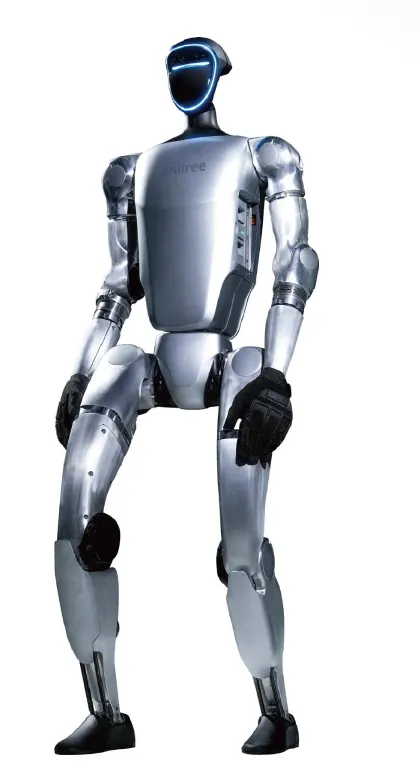
Full humanoid structure
Up to 52 degrees of freedom for complex motions and full-body coordination.
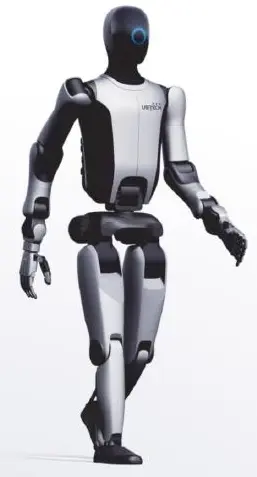
UBTECH · Open humanoid platform
High-payload and precision operation platform.
An open humanoid robot platform for industrial scenarios.
52
Total degrees of freedom
≤15 kg
Dual-arm payload
275 TOPS
AI computing
≥3.5 h
Endurance
Core advantages
Up to 52 degrees of freedom for complex motions and full-body coordination.
High-performance joints for both dynamic execution and stability.
Autonomous battery swapping and long-duration operation.
Joint control, locomotion and navigation APIs with sample code.
Imitation learning, reinforcement learning, VLA and real-world deployment.
Multi-capability coordination and task orchestration.
Hardware
4-inch circular display (720 × 720), mic array × 4 and speaker × 2.
Data and ecosystem
Closed-loop data acquisition based on teleoperation and data platforms, with standardized datasets from multiple factories and environments.
Multiple facilities provide continuous data acquisition.
Cloud workflow from training to simulation and evaluation.
Joint R&D, workshops, training camps and competitions.
From technical validation to real-world commercial deployment.
Applications
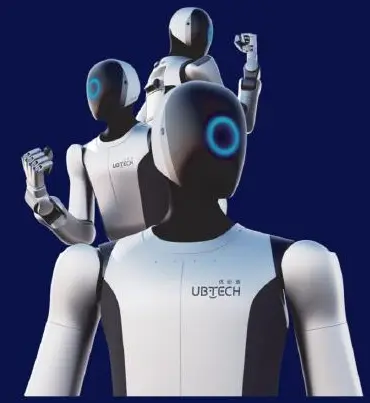
Data processing, algorithm development, model optimization and teaching practice.
Secondary development, application building, system integration and scenario deployment.
Handling and sorting, inspection, human–robot collaboration and industrial data acquisition.
| Specification | Value |
|---|---|
| Height · weight | 176 cm · ≈70 kg |
| Degrees of freedom | 52 total · 7 per arm · 6 per leg |
| Dual-arm payload | ≤15 kg |
| End-effectors | Five-fingered dexterous hand, two-fingered gripper, gripper plate |
| Specification | Value |
|---|---|
| Cameras | 1MP camera × 4, RGB-D camera × 2, wrist-mounted camera |
| Sensors | High-precision IMU, pose sensor × 2, six-axis force sensor × 2 |
| Screen · voice | 4-inch circular display (720 × 720) · mic array × 4, speaker × 2 |
| Specification | Value |
|---|---|
| Battery · endurance | 48 V 7 Ah LiFePO4 × 2 · ≥3.5 h |
| Computing | Intel i7 onboard · 275 TOPS AI computing |
| Communications · middleware | Wi-Fi/5G · ROSA 2.0 · open interface |
| Supported capabilities | Autonomous battery swap, carrying, sorting, squatting, depalletizing, palletizing, navigation |
Gallery
Get in touch
Talk to our integration experts about deploying AI platforms, quantum solutions, robotics, or educational labs across your organization.