Stability01
Stability
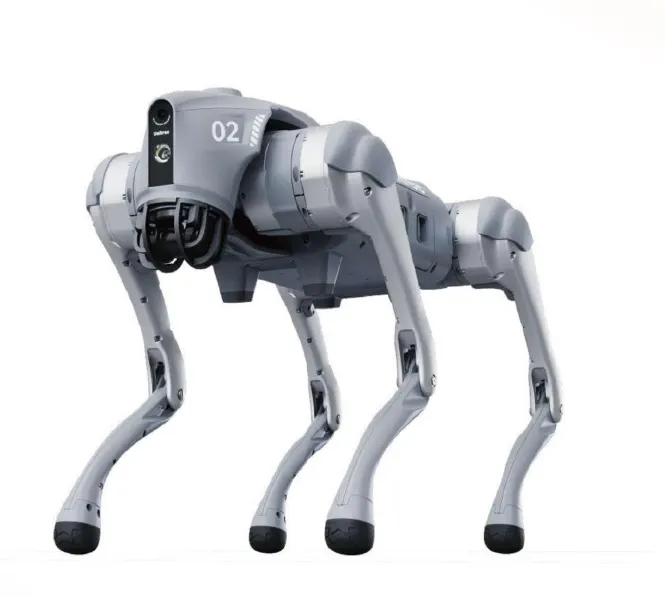
Tripod gait keeps three legs grounded with dynamic centre-of-gravity control and anti-disturbance recovery.
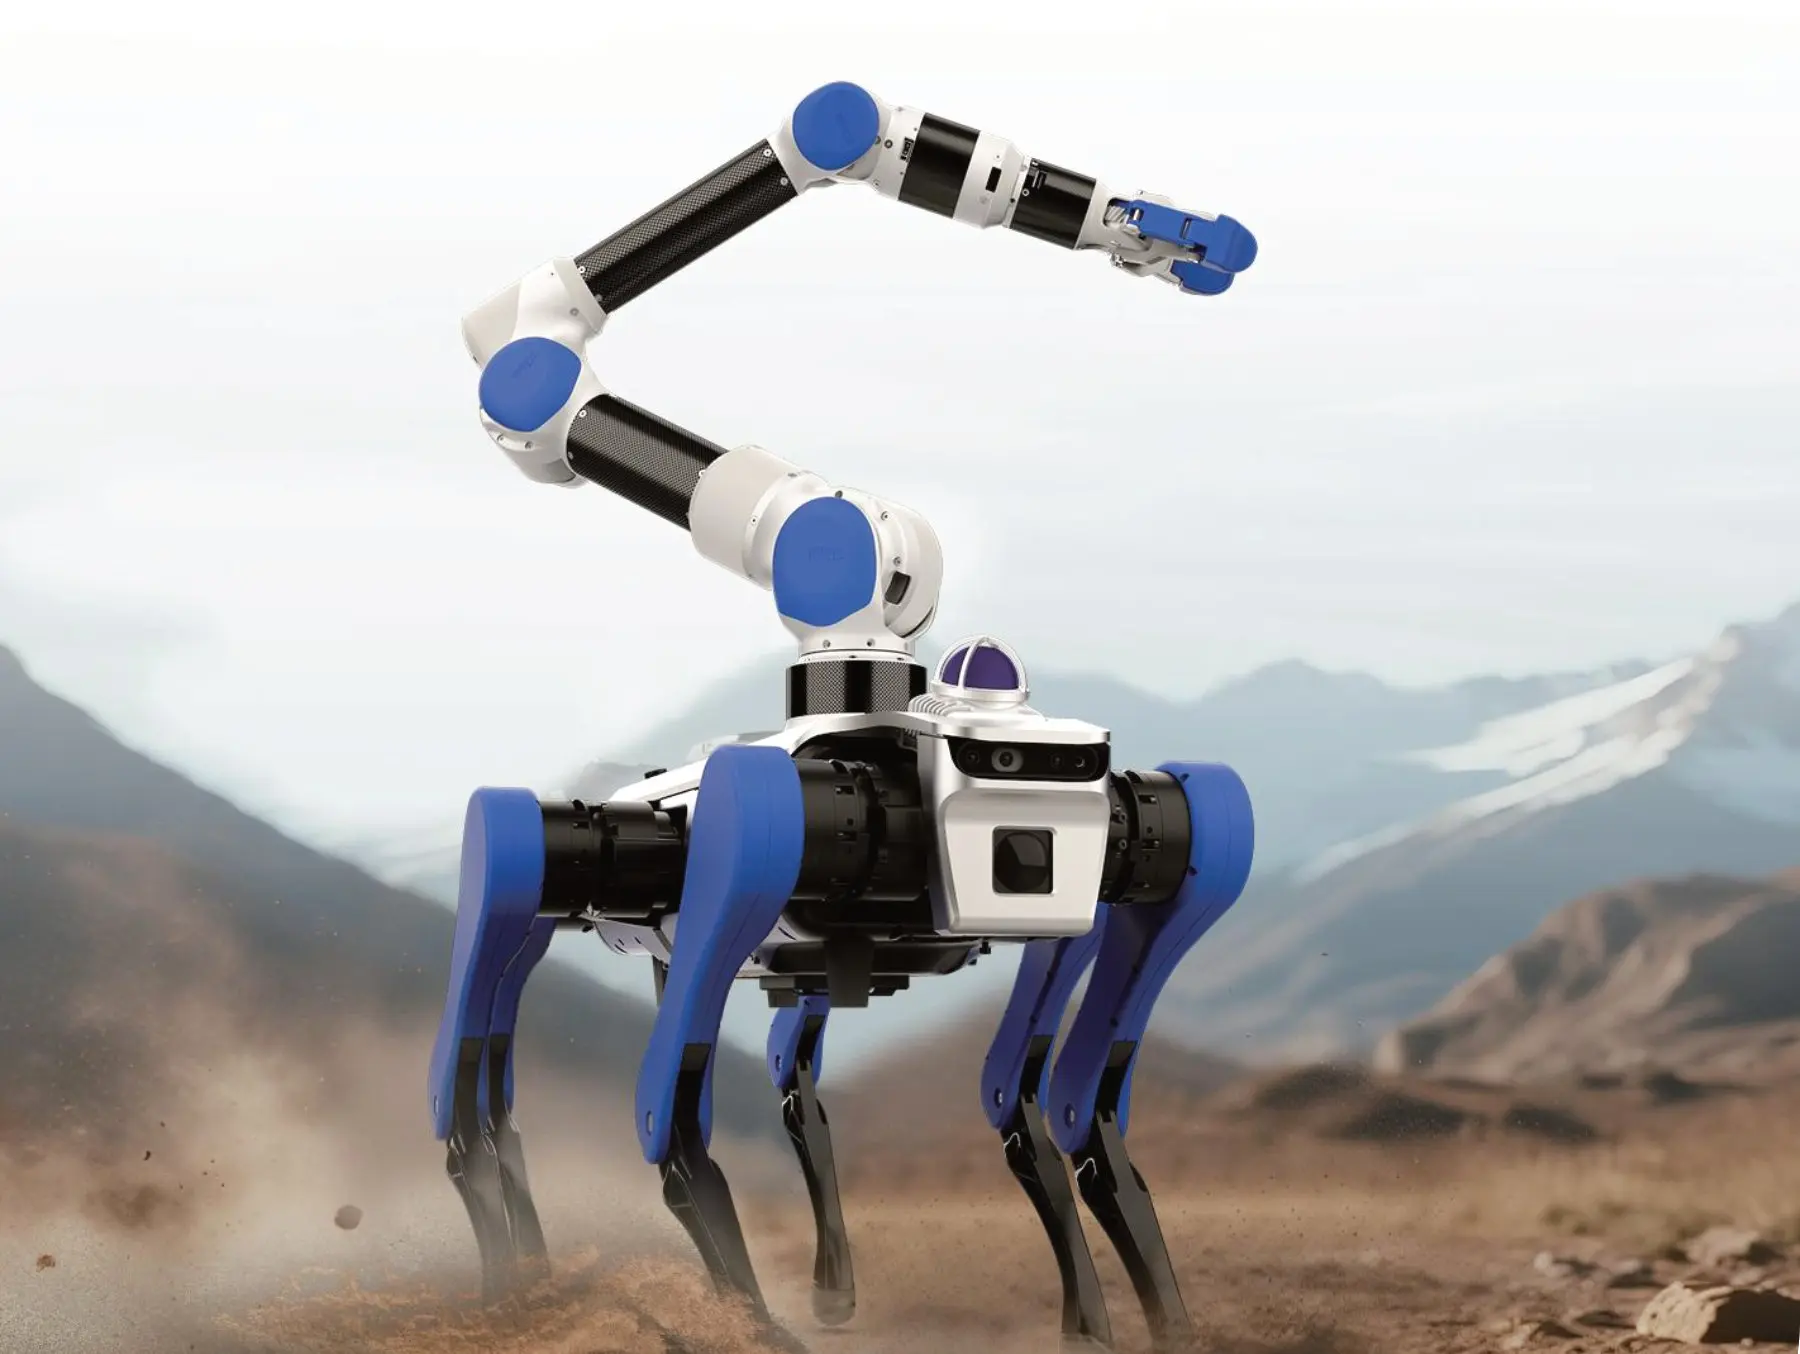
DOBOT · Robotics & integration
Six legs. More possibilities.
Tripod gait keeps three legs grounded with dynamic centre-of-gravity control and anti-disturbance recovery. 10 kg rated and 15 kg maximum payload. The presentation describes pulling five times its own weight.
18
DOF
1.8 m/s
Maximum walking speed
10 / 15 kg
Rated / maximum payload
2.5 h
Battery life
Product capabilities
Tripod gait keeps three legs grounded with dynamic centre-of-gravity control and anti-disturbance recovery.
10 kg rated and 15 kg maximum payload. The presentation describes pulling five times its own weight.
Low-impact gait and noise-optimized motors; operating specification ≤55 dB, with the feature slide citing as low as 50 dB.
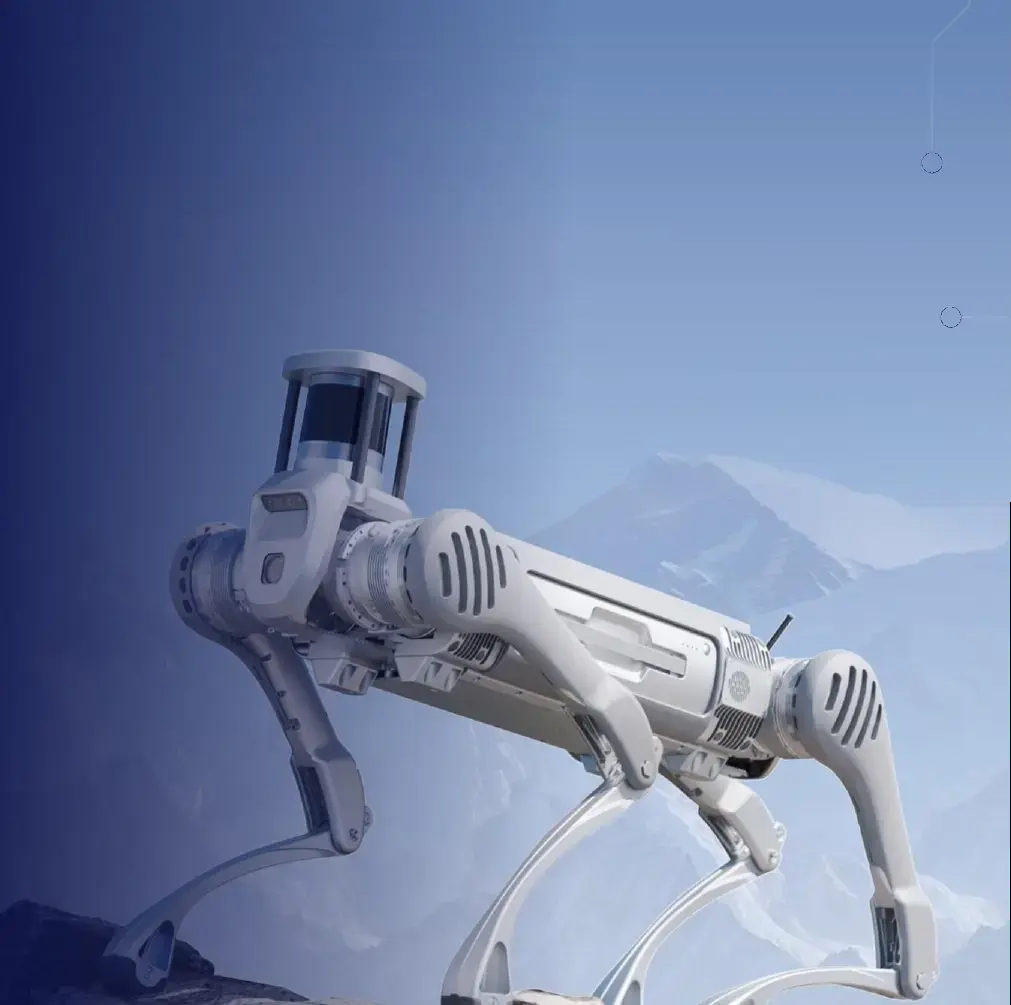
Adaptive gait uses LiDAR, depth camera, IMU and proprioception for grass, sand, wet ground and gravel.
Explore the system
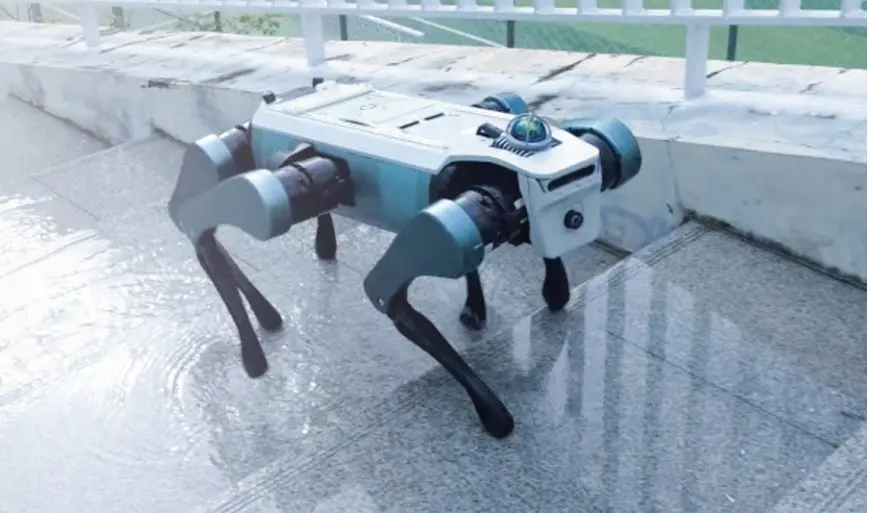
Tripod gait keeps three legs grounded with dynamic centre-of-gravity control and anti-disturbance recovery.
Applications & learning
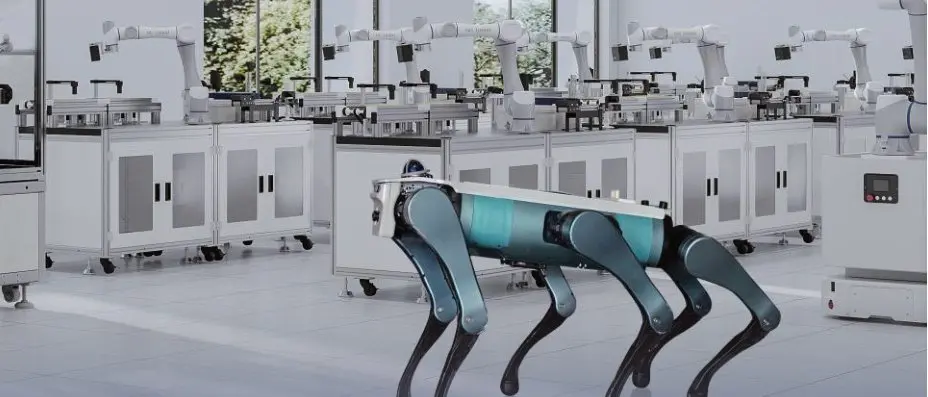
Multidisciplinary development, testing and robotics simulation.
Voice-guided tours and route planning in museums and science centres.
Repetitive patrols in parks, stations, substations and tunnels.
Field exploration and civilian reconnaissance, search and fire-emergency scenarios listed in the deck.
| Specification | Value |
|---|---|
| Dimensions | Standing 86.3 × 47 × 48 cm · folded 73.4 × 47 × 24.4 cm |
| Weight | ≈20 kg net · ≈30 kg packed |
| DOF | 18 |
| Speed | 1.8 m/s |
| Obstacle height | 20 cm |
| Maximum slope | 40° |
| Rated / max payload | 10 / 15 kg |
| Battery | 504 Wh · 2.5 h |
| Knee motor peak torque | 33 N·m |
| Operating noise | ≤55 dB |
| Joint range | Front/mid hip −60° to 180° · rear −60° to 239° · lower leg −30° to −160° · body tilt ±38° |
| Control platform | x86_64 · Intel Core i7/i5 · 6 cores / 16 threads · GPU 40 TOPS |
| Sensors | Livox Mid360 · Intel RealSense D435 RGB-D · speaker |
| SDK | Ubuntu 22.04 · ROS2 Humble · Python / C++ |
| Tools & data | ROS2 / MuJoCo simulation · debugging · motion, IMU, joint and sensor data |
Cobot arm integration, long-range remote/image transmission and wireless automatic charging are future expansions, not standard equipment.
Product gallery
Get in touch
Talk to our integration experts about deploying AI platforms, quantum solutions, robotics, or educational labs across your organization.