Grasp01
Mobile grasping
Versatile 6-axis arm for precise mobile grasping.
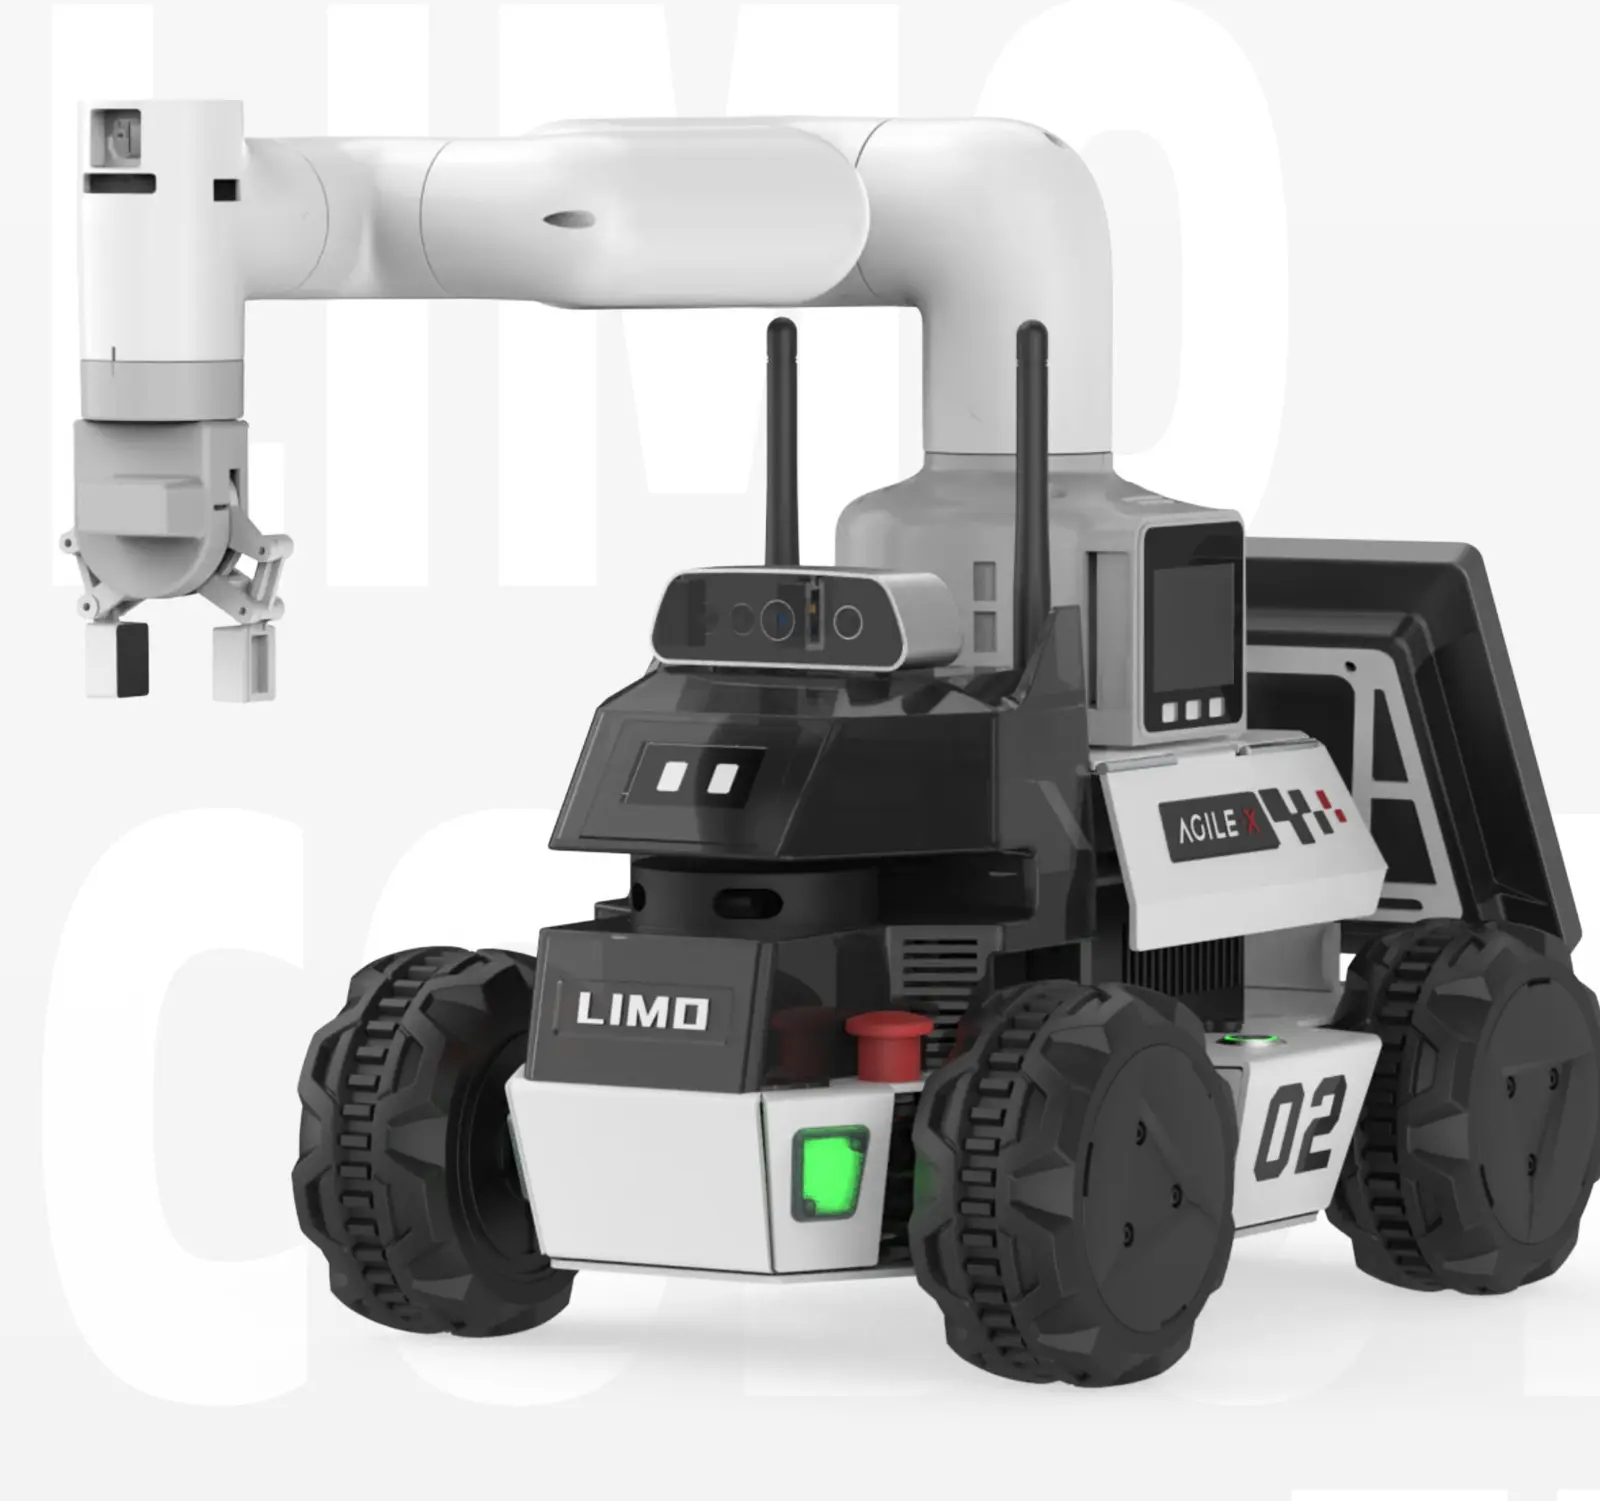
AgileX · Mobile manipulation
Drive, map, then grasp.
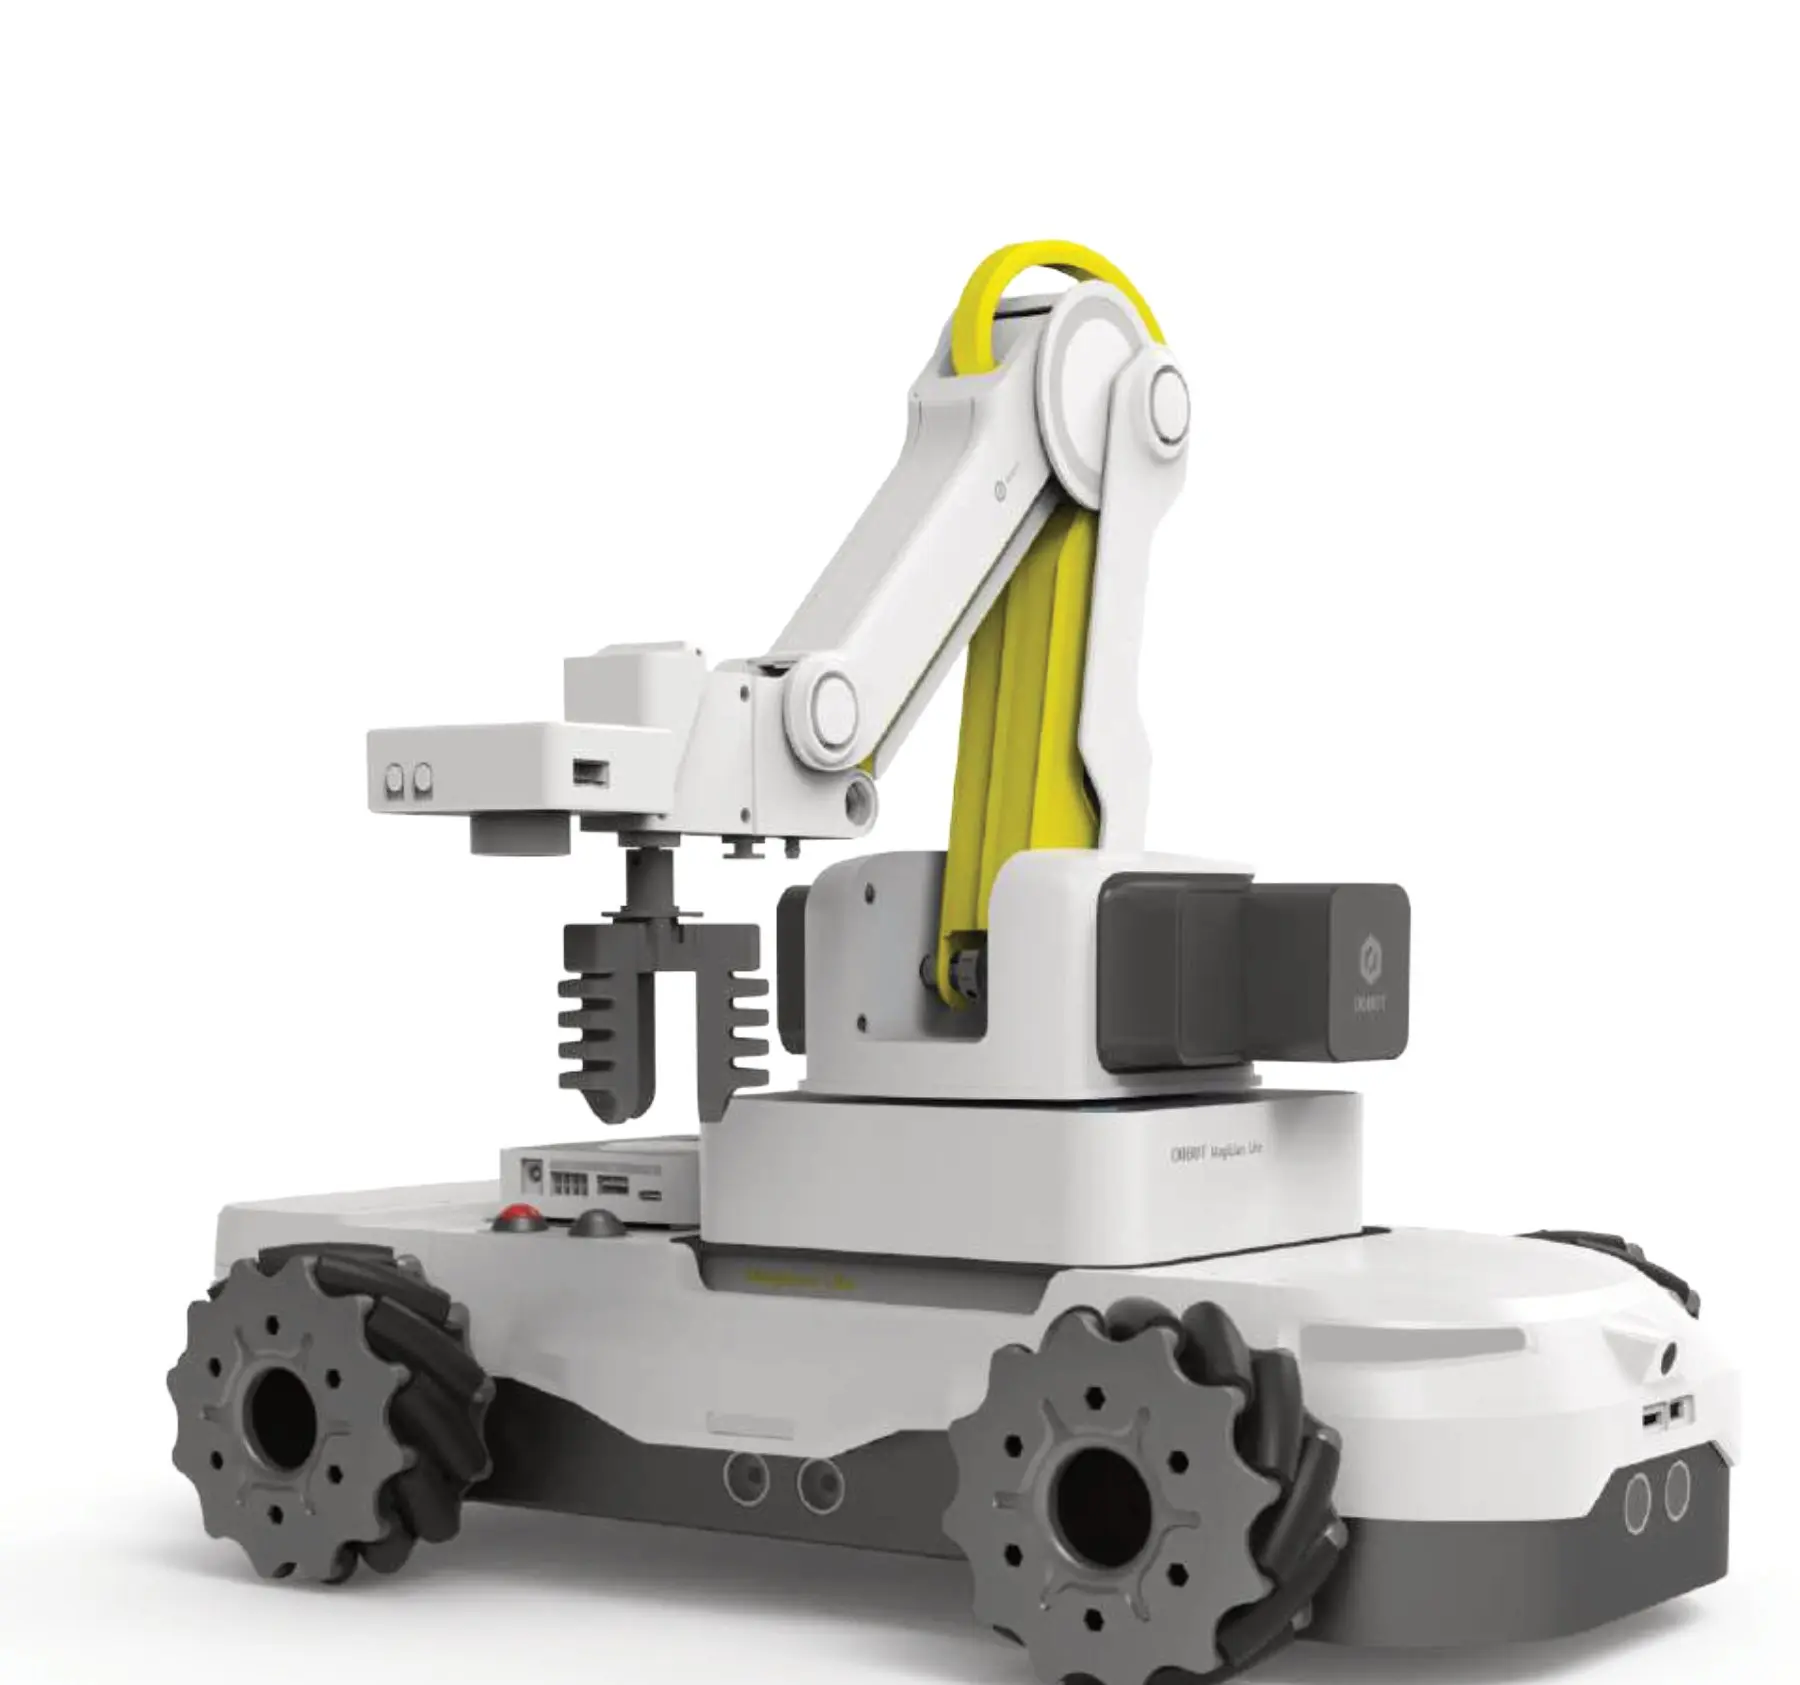
Multi-modal ROS mobile manipulator: LIMO PRO + myCobot 280.
6-DOF
Arm
±0.5 mm
Arm accuracy
1–2 cm
Parking accuracy
5.6 kg
Total weight
Key capabilities
Versatile 6-axis arm for precise mobile grasping.
Creates accurate maps for navigation in complex spaces.
Senses surroundings and navigates around obstacles.
ROS, Gazebo, Python and C++; navigation, mapping, localization and MoveIt tutorials.
Supplied, installed, integrated and supported in Egypt by GateIn Technology, exclusive AgileX partner for Egypt.
Explore the hardware
6-DOF + gripper, 280 mm radius, 250 g working load.
Application scenarios
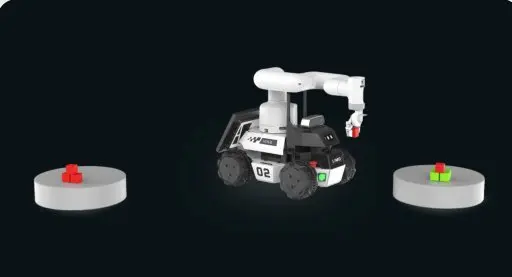
Pick objects after driving to them autonomously.
LiDAR SLAM and visual SLAM on the simulation table.
Python, C++ and MoveIt tutorials included.
| Specification | Value |
|---|---|
| Total weight · dimensions | 5.6 kg · 322 × 220 × 550 mm |
| Arm | 6-DOF + gripper · 0.8 kg |
| Arm working accuracy · radius | ±0.5 mm · 280 mm |
| Working load | LIMO 4 kg · arm 250 g |
| Navigation · parking accuracy | LiDAR SLAM, visual SLAM · 1–2 cm |
| Communication | LIMO USB · arm Type-C |
| Specification | Value |
|---|---|
| Load capacity · ground clearance | 4 kg · 24 mm |
| Computer · depth camera · LiDAR | NVIDIA Orin Nano · Orbbec DaBai · EAI T-mini Pro |
| Battery · operating · standby | 10 Ah 12 V · 2.5 h · 4 h |
| System · ROS | Ubuntu 20.04 · ROS1 Noetic / ROS2 Foxy |
| Speed · control | 1 m/s · mobile app / command, 10 m range |
Product gallery
Get in touch
Talk to our integration experts about deploying AI platforms, quantum solutions, robotics, or educational labs across your organization.